NAG-002161 · Accepted whole
The pointwise endpoint
5 Tropicalization, multiplicities and balancing
Open in the English reader · PDF page 880
Statement · exact TeX
\begin{lemma}[\bi{The pointwise endpoint}
{逐点终点}]
\label{cand:etaledisplacementpointwiseendpoint}
\bi{For every $x\in\mathcal M(B)$, the formula}
{对于每个 $x\in\mathcal M(B)$,公式}
\[
 |b(H_B(x,1))|=\sup_\nu|D_\nu(b)(x)|
             =\lim_{t\uparrow1}|b(H_B(x,t))|
\]
\bi{defines a point of $\mathcal M(B)$ and extends its
trajectory continuously to $[0,1]$. Each endpoint evaluation
is lower semicontinuous as a function of $x$. The endpoint
commutes with all strict-time maps and is idempotent:}
{定义 $\mathcal M(B)$ 中的点,并将该点的轨迹连续
延拓到 $[0,1]$。每个终点取值作为 $x$ 的函数下半
连续。终点与全部严格小于一时刻的映射相容,且为
幂等映射:}
\[
 H_B(H_B(x,1),t)=H_B(x,1)=H_B(H_B(x,t),1),
                 \qquad 0\leq t\leq1.
\]
\end{lemma}
Full selected proof · exact TeX
\begin{proof}
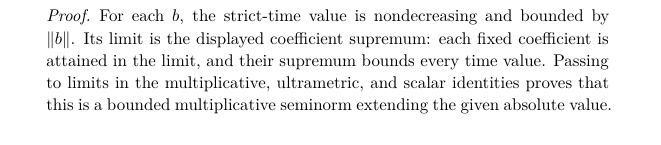
\bi{For each $b$, the strict-time value is nondecreasing
and bounded by $\|b\|$. Its limit is the displayed
coefficient supremum: each fixed coefficient is attained in
the limit, and their supremum bounds every time value.
Passing to limits in the multiplicative, ultrametric, and
scalar identities proves that this is a bounded multiplicative
seminorm extending the given absolute value. Evaluation
topology gives convergence to its point, hence continuity
of the trajectory at time one. A supremum of continuous
coefficient evaluations is lower semicontinuous.}
{对每个 $b$,严格小于一时刻的取值单调不减,且被
$\|b\|$ 控制。其极限等于所列系数上确界:每个固定
系数都在极限中达到,而这些系数的上确界控制每个
时刻的值。在乘性、超度量及标量恒等式中取极限,
得到延拓原绝对值的有界乘性半范数。取值拓扑给出
向其对应点的收敛,故轨迹在时刻一连续。连续系数
取值的上确界为下半连续函数。}

\bi{Fix $t<1$. Continuity of the strict-time map in $x$
and Proposition~\ref{cand:etaledisplacementfunctoriality}
allow $s\uparrow1$ in
$H_B(H_B(x,s),t)=H_B(x,\max(s,t))$. The resulting identity
is $H_B(H_B(x,1),t)=H_B(x,1)$. In the opposite order,
pointwise convergence applied to the fixed point $H_B(x,t)$
gives $H_B(H_B(x,t),1)=H_B(x,1)$. Finally let $t\uparrow1$
in the first equality, again using the continuous trajectory
of the fixed point $H_B(x,1)$, to get idempotence.}
{固定 $t<1$。严格小于一时刻的映射关于 $x$ 连续,
故可在 Proposition~\ref{cand:etaledisplacementfunctoriality}
的等式 $H_B(H_B(x,s),t)=H_B(x,\max(s,t))$ 中令
$s\uparrow1$,得到 $H_B(H_B(x,1),t)=H_B(x,1)$。
对反向次序,将逐点收敛用于固定点 $H_B(x,t)$,得到
$H_B(H_B(x,t),1)=H_B(x,1)$。最后在第一个等式中
令 $t\uparrow1$,利用固定点 $H_B(x,1)$ 的轨迹
连续性,得到幂等性。}
\end{proof}
Standing context 1 · exact TeX
\bi{Retain the standard algebra $A$ and its integral coordinates
from Lemma~\ref{cand:mixedgaussdisplacement}. Let
$F=(F_1,\ldots,F_m)$ be represented by restricted series in
$X_0,\ldots,X_r,T,Y_1,\ldots,Y_m$ with coefficients in
$K^\circ$. Write $J=\partial F/\partial Y$ and consider the
nonzero affinoid algebra}
{保留 Lemma~\ref{cand:mixedgaussdisplacement} 中的标准代数
$A$ 及其整坐标。设 $F=(F_1,\ldots,F_m)$ 由变量
$X_0,\ldots,X_r,T,Y_1,\ldots,Y_m$ 的受限级数表示,
系数属于 $K^\circ$。写 $J=\partial F/\partial Y$,并考虑
非零 affinoid 代数}
\[
 B=A\langle Y_1,\ldots,Y_m,Q\rangle/
                  (F_1,\ldots,F_m,Q\det J-1).
 \tag{J}\label{eq:candetalejacobianpresentation}
\]
\bi{We use its displayed quotient norm. In particular the
coordinate images and $J^{-1}=Q\operatorname{adj}(J)$ have
norm at most one. All the statements below keep this
presentation over the original valued field.}
{使用所列表示的商范数。特别地,坐标像及
$J^{-1}=Q\operatorname{adj}(J)$ 的范数至多为一。下述
全部陈述保留原赋值域上的这个表示。}
Typeset reader excerpt
Typed proof inputs
- NAG-002158 · selected whole (earlier independently reviewed original whole in this tier)
- NAG-002160 · selected whole (earlier independently reviewed original whole in this tier)
- NAG-002158 · selected whole
- NAG-002158 · selected whole (requires)
- NAG-002160 · selected whole
- NAG-002160 · selected whole (requires)
Reader cross-references
Proof map
Verified map inputs · NAG-002161
AND · joint registered proof inputs
- NAG-002158 · The strict-time analytic lift · accepted whole
- NAG-002160 · Functoriality and the composition law · accepted whole